How To

124 articles

Procedural, step-by-step instructional tutorials designed to assist power users and technicians in software configuration, hardware deployment, and workflow automation. We provide clear, structured guides that resolve technical challenges and foster self-sufficient technical troubleshooting.

Advertisement
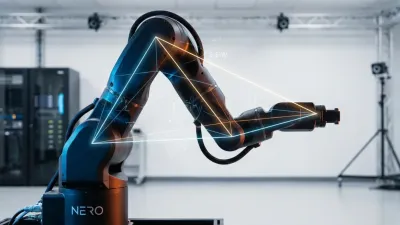
Build a Real-Time 7-DoF IK Solver for the NERO Robotic Arm in ROS2

Build a Real-Time 7-DoF IK Solver for the NERO Robotic Arm in ROS2

Calculating inverse kinematics for redundant robotic arms usually requires heavy iterative math. This closed-form geometric approach uses elbow angle parameterization to bypass Jacobian matrices entirely - delivering real-time, collision-free motion for 7-DoF systems....

Advertisement
Advertisement