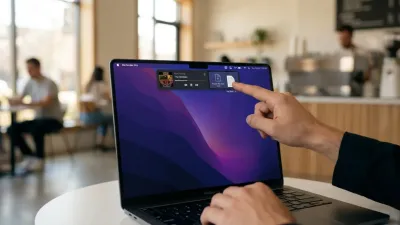
Bartender Pro Transforms the MacBook Notch Into a Dynamic Island
Drag files directly into the notch, track AI agents like Claude Code, and manage your clipboard. Bartender Pro proves Apple's dead screen space is actually a massive UX opportunity....
May 13, 2026
 25
25